Chinese NEVS buys leading in-wheel electric motor manufacturer

Protean in-wheel electric motorNational Electric Vehicles Sweden announced last week that it has bought Protean, a British manufacturer of in-wheel motors for electric cars. In announcing the tie-up with NEVS, Protean said the acquisition will speed the rollout of its technologies in next generation electric and self-driving cars, and "paves the way for NEVS to deploy Protean...

Honda’s all-electric NSX 4-Motor EV is more advanced than any Tesla

Honda's head of research and development, Sekino Yosuke, has revealed the next-generation Honda NSX could be based on the firm’s 1,000 hp Pikes Peak race car, the NSX-inspired 4-Motor Acura EV Concept.

The 4-Motor Acura EV finished third overall at the Pikes Peak hill climb in 2016. That was thanks to its all-electric all-wheel-drive powertrain, comprising four electric motors that developed around 740 kW and 800 Nm of torque, a 70 kwh lithium-ion battery pack and only 1,500 kg kerb weight. Honda claims the electric NSX is capable of 0-100 km/h in 2.5 seconds and 0-200 km/h in 6.2 seconds.

With the current all wheel drive hybrid NSX having only been on sale since last year, an all-new NSX is unlikely to be launched before 2023, when battery technology is expected to have progressed significantly.

Honda first demonstrated a 4-Motor EV CR-Z prototype in 2015 with journalists who test drove the vehicle suggesting torque vectoring gave it cornering ability in a whole other league to a Model S.

While there's no denying Tesla, especially with ludicrous mode, have re-calibrated the auto-industry's definition of 'quick', it's probably less well known that Tesla's powertrain is actually based on 1990s technology with the 3 phase AC induction motor and controller designs originally licensed from EV1 drive system engineer Alan Cocconi.

Unlike current high performance all-wheel drive electric vehicles, like Tesla's Model S P100D, which use 2x motors and conventional mechanical differentials, Honda's electric NSX features four electric motors — one for each wheel.

With a dedicated motor at each corner, the Super Handling All-Wheel Drive (SH-AWD) system can precisely apply either positive or negative torque individually to each wheel. This opens the door to torque vectoring and full-time active yaw control - something that will make consumer EVs safer and more energy efficient.

How does this work? Imagine electronic stability control that, instead of applying friction brakes (wasted energy), applies negative torque (regenerative braking) to individual wheels. Unlike friction-brake based ISC, the NSX 4-Motor system can also apply positive torque to individual wheels. Combining that range of precise control with a multi gyro inertial measurement platform unlocks an entirely new level of safety and high performance active dynamic control.

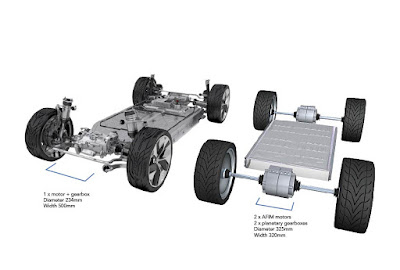
While it might be another 5-6 years before Honda's 4-Motor Super Handling All-Wheel Drive makes it into production, the team at Evans Electric are developing an AWD torque vectoring system based on compact Axial flux induction motors.

Sydney Airport Launch new Electric Bus Fleet for 2017

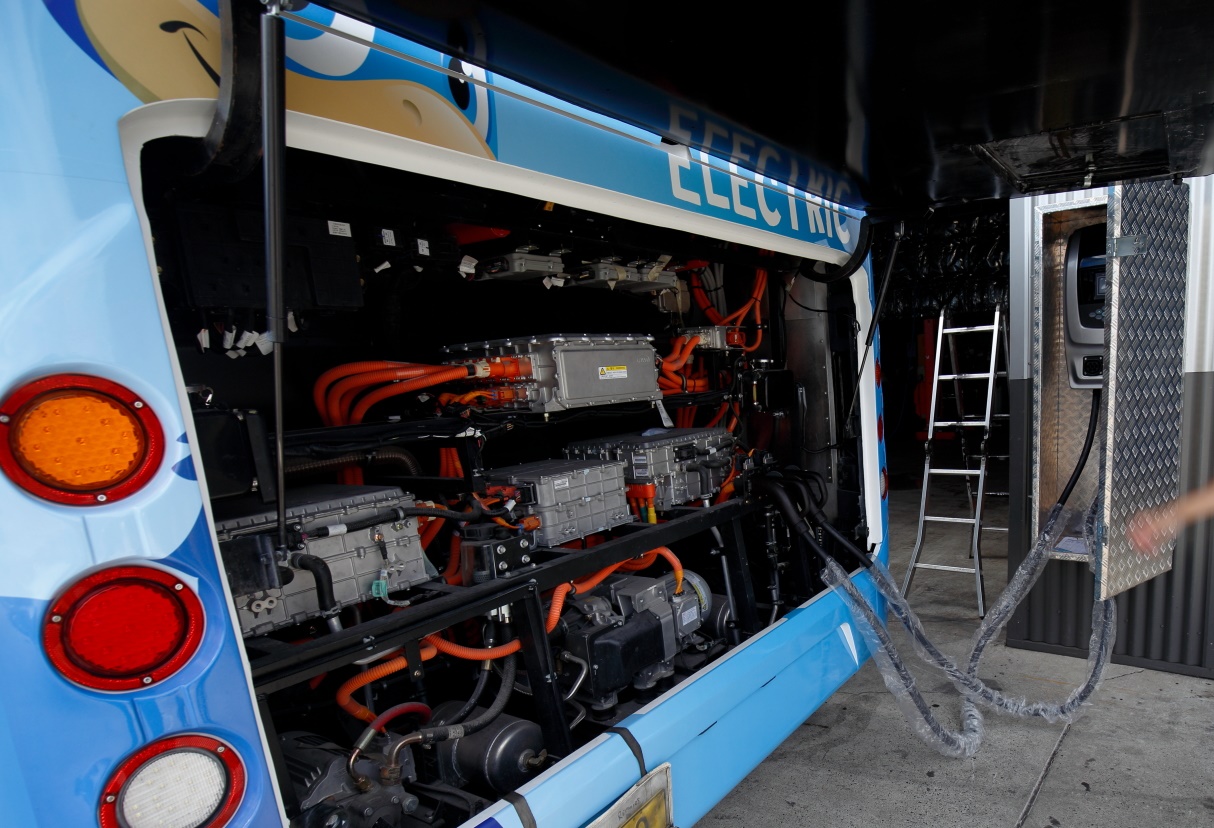
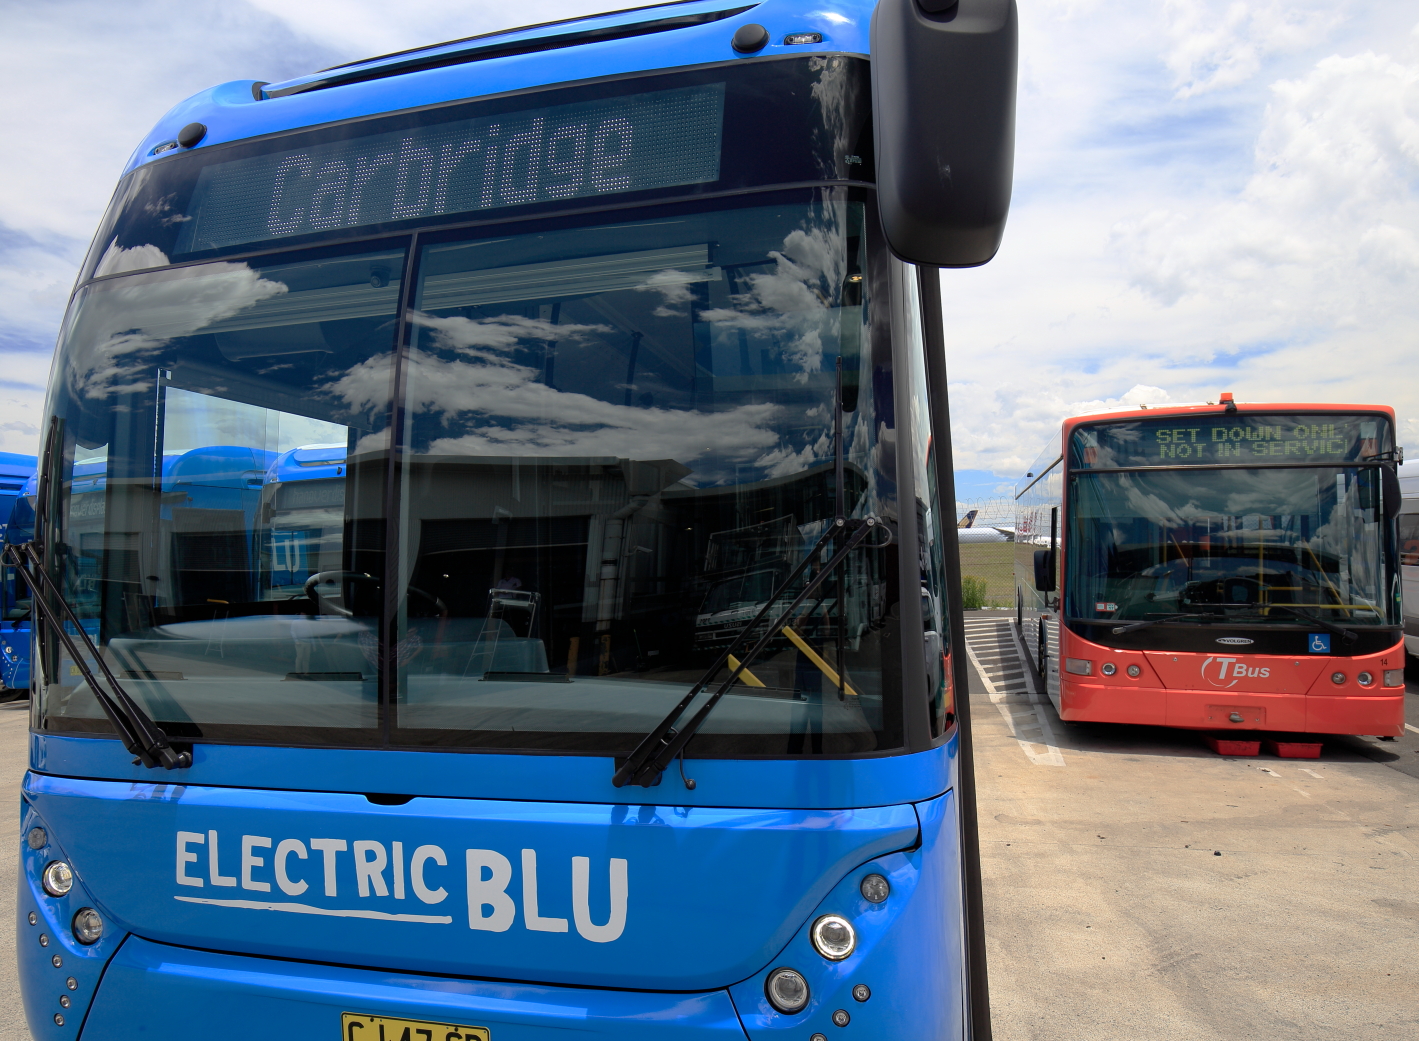
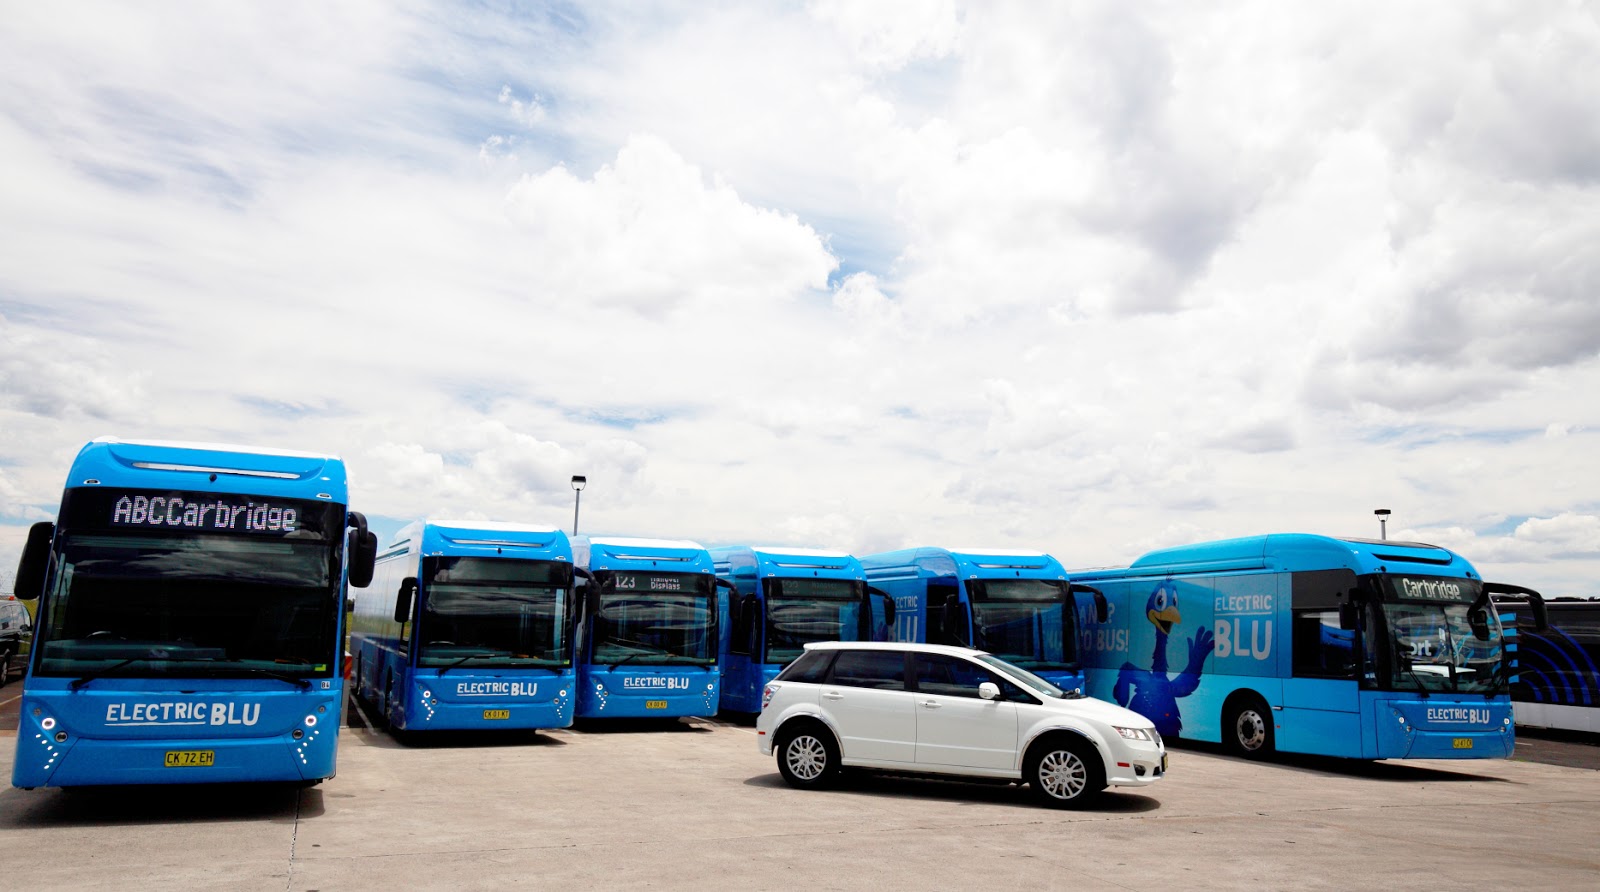
EV News was recently invited to preview the largest fleet of electric buses in Australia. Built by airport bus operator Carbridge in partnership with Gemiland coachworks and BYD, the new fleet of six battery powered buses are owned by Sydney Airport Corporation Limited as part of a $5 million investment in environmentally friendly ground transportation technology.

With a carrying capacity of 70 passengers, each bus has a range of 500 kilometres, making up to 100 transfer journeys on a single charge. The fleet will provide transportation for over two million travellers, visitors and airport workers who use the Blu Emu shuttle service every year.

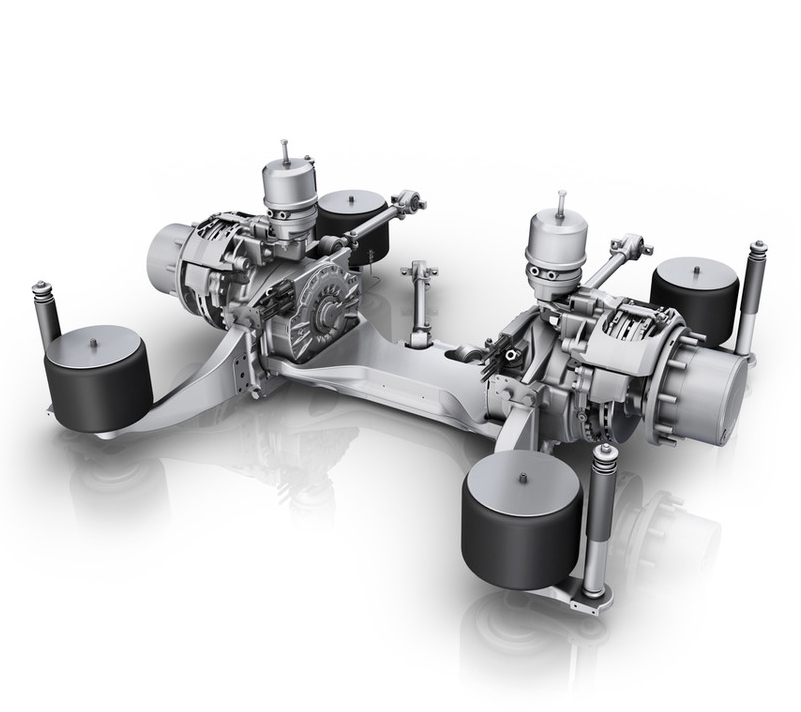
The Electric Blu Toro buses, manufactured by a joint venture between BYD & Carbridge, feature custom Gemiland bus-bodies fabricated from aero-grade aluminium for significant weight reduction. The BYD chassis comprises a ZF front axle and a ZF clone rear axle featuring dual 90 kW / 350 Nm water cooled permanent magnet wheel-hub traction motors. A maximum motor shaft speed of 7,500 rpm coupled to the rear wheels via a two stage 17.7 to 1 planetary gear hub provides surprisingly rapid acceleration and a top speed of 70 km/h.

Energy storage is via a 324 kWh BYD iron phosphate battery with the pack split between the forward roof and rear engine compartment zones connected in parallel for a bus voltage of 400 vdc. Dual BYD 40 kW Mennekes AC chargers provide 80 kW fast charging via the dual traction inverters.

The new electric blu buses will replace the airport’s existing diesel bus fleet servicing the 7 km shuttle route between the T2/T3 terminal precinct and the Blu Emu Car Park.

Driverless Car Hype Machine or Augmented Drive-by-wire?

While monitoring the 24/7 Internet news cycle it seems not an hour goes by without another 'news' story about driverless cars, usually showing someone behind the controls grinning from ear-to-ear with their hands off the steering wheel like they're riding a roller coaster. The fact that these systems are merely an advanced form of cruise control never seems to penetrate the reality distortion field generated by the hype machine pushing these stories.

History

Speed regulating cruise control (originally named “Auto-pilot”) was first put into a production car almost 60 years ago. Lane Keeping Assist features were first introduced almost 25 years ago. A Honda version of LKAS that provided 80% of steering torque to keep the car in the lane on highways has been on the market since 2003.

Similarly autonomous cruise control with auto brake features was also first introduced 25 years ago and there are now 15+ auto brands offering these systems. Even cars that park themselves have been on-sale for over a decade. (2003 Toyota Prius) Yet as we're about to hit 2017 these functions still has enough novelty value that some media types have branded them 'robot cars'??

Google

Self driving car (SDC) hype really leapt off the Richter scale when Google acquired a startup called 510 systems in 2008. A small team of UC Berkeley students with DARPA Challenge experience built a robotized Toyota Prius called “PriBot” for a TV show pizza delivery stunt.

It's clear that choosing a Toyota Prius to become the first road legal SDC was a strictly functional decision. The mass market adaption of hybrid and electric vehicle brake regeneration has played a large role in enabling self driving cars. The two features that allow relatively easy implementation of robotic control in production cars are 1) electric power steering 2) brake-by-wire regenerative braking. In conjunction with by-wire throttle, these systems allow direct control of steering, acceleration & moderate braking via low-voltage electronic signals that can be generated in software. This is why all SDC's are either hybrid or electric cars.

What is less clear is how well self driving cars handle emergency situations. Despite hybrids and EVs primarily using regen braking to the extent that brake pads now last the life of the vehicle, anti-lock brakes and stability control functions are still part of the legacy friction brake system that requires human muscle input to activate. The work-around has been to restrict Google prototype testing speeds to 25 mph (40 km/h) and requiring a safety drivers onboard at all times.
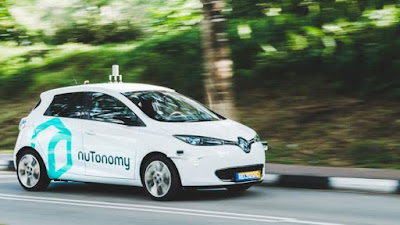
Despite the fact nine US states have passed legislation to allow public road testing of 'driverless' cars, by some estimates, Google cars are unable to use about 99% of US roads. Aside from their inability to drive in anything but perfect weather conditions, the cars do not carry the computing horsepower to process all the required data in real-time so the car’s exact route must be extensively mapped. Data from multiple passes by a special sensor vehicle must be pored over, meter by meter, by both computers and humans before any SDC can test a new route. It’s vastly more effort than what’s needed for Google Maps.

While there are half a dozen public 'trials' of self-driving cars/shuttles active around the world , they are either on private roads/campuses or if on public roads, they run in very geographically limited areas. None of them are strictly speaking 'driverless' as they all have human 'safety' drivers.

Safety

The original goal for Google's SDC program, as stated by the “godfather” of self-driving Sebastian Thrun, was to promote safety. Most definitely a laudable goal, but is a map localising cruise control really the best solution to reduce 1 million road deaths and 50 million serious injuries every year?

Real world evidence is starting to suggest, maybe not! A long read by Tim Harford published by The Guardian makes the case that too much automation increases driver in-attention to the point that responding to emergency situations becomes more dangerous, a situation known as the automation paradox.

While governments around the world are cracking down on driver distractions like texting while driving, with the UK now suggesting that offenders could face a life sentence, self-driving/auto-pilot systems actively promote in-attention by lulling drivers into a false sense of security.

The fact is that while SDC systems are designed to replace the driver, they do nothing to improve functional vehicle safety. SDC's still has the same mandatory mechanical friction brake based anti-lock and stability control systems as any other car on the road. A self-driving system has the same three basic controls to operate a vehicle as a human driver, yet with the introduction of electric vehicles the potential is there to develop augmented digital by-wire control systems that can bring commercial aviation levels of safety to the automotive world.

Fly-by-wire was developed 50 years ago for aerospace during the Apollo program. Augmented fly-by-wire electronic control systems aid and protect aircraft in flight via 'control laws' that provide flight envelope protection, a human machine interface (HMI) that prevents a pilot from making control commands that would force the aircraft to exceed its structural and aerodynamic operating limits. These augmented HMI systems are standard equipment on commercial aircraft and today’s impressive safety and reliability statistics are a testimony to the advanced technology represented in fly-by-wire digital flight control systems. Yet despite the ever increasing level of electronics in ICE powered vehicles, they are still primarily direct control mechanical systems with some limited power assistance.

Electric Vehicles

The introduction of electric powertrains opens the opportunity for augmented drive-by-wire control via primarily solid-state electric powertrains. Replacing mechanical friction brakes with electromagnetic braking by incorporating an electric motor for each individual wheel, either in-board or in-wheel, establishes a direct digital connection that allows precise control of vehicle dynamics and takes human muscle strength out of the loop. This allows a rules based augmentation system to compensate for a drivers lack of knowledge and/or skill while providing a 'guardian angel' to protect drivers from exceeding a vehicles dynamic limits, or in some cases can assist them in reaching those limits.
In 1992, Daimler-Benz performed a study that utilised its driving simulator in Berlin, which revealed some striking data about simulated panic stops and crashes. In the study, more than 90% of the drivers failed to apply enough pressure to the brakes when faced with emergency situations. This is co-incidentally the same figure the SDC industry often quotes, “some 90% of motor vehicle crashes are caused by human error.”

Based on the Daimler study it seems clear that despite the fact drivers react to emergencies, their lack of training/familiarity with either the braking effort required and/or the capability of the vehicles braking system is the cause of the majority of road accidents. In 1996 Mercedes-Benz introduced yet another extension to hydraulic brakes called Emergency Brake Assist which compensates for 1) human leg muscle strength still being required to operate a modern automobile 2) the "buzzing" feedback and sinking brake pedal during ABS operation.

So does a hybrid brake-by-wire system qualify as an advance that removes human leg muscles from the loop? For moderate brake applications yes, but because brake regeneration is limited by battery charge rates to 50-60 kw max, under emergency braking the car defaults back to the legacy hydraulic friction brake system with it's plethora of add-on systems like ABS, ESC, EBA, EBD etc that, while power assisted, still requires leg muscle strength.

I have previously discussed how hydraulic friction brakes on hybrid and electric vehicles are effectively redundant, yet because of regen limits a Google self-driving Toyota Prius would only be able to perform moderate braking under computer control, requiring human leg-muscle input for emergency braking, which seems to defeat the advertised purpose of the program?

A drive-by-wire quad motor electric powertrain could provide a machine to machine (M2M) / human to machine interface (HMI) that would require no more leg effort to execute an emergency stop from any speed than operating a throttle pedal, while also incorporating all mandatory safety features in software to be executed via brake-mode torque vectoring all while keeping the vehicle within it's safe dynamic envelope. A drive-by-wire powertrain would provide a platform for map localising algorithms and various 3D sensor hardware to work together in a similar fashion to aircraft auto-pilot and rules based augmented fly-by-wire in commercial aviation. Drive-by-wire would provide a certifiable advanced computer control system to monitor and step-in to assist drivers to improve road safety while we're all waiting the next 10-20-30 years for consumer ready self-driving cars.

Evans Electric previews new Axial Flux EV motor

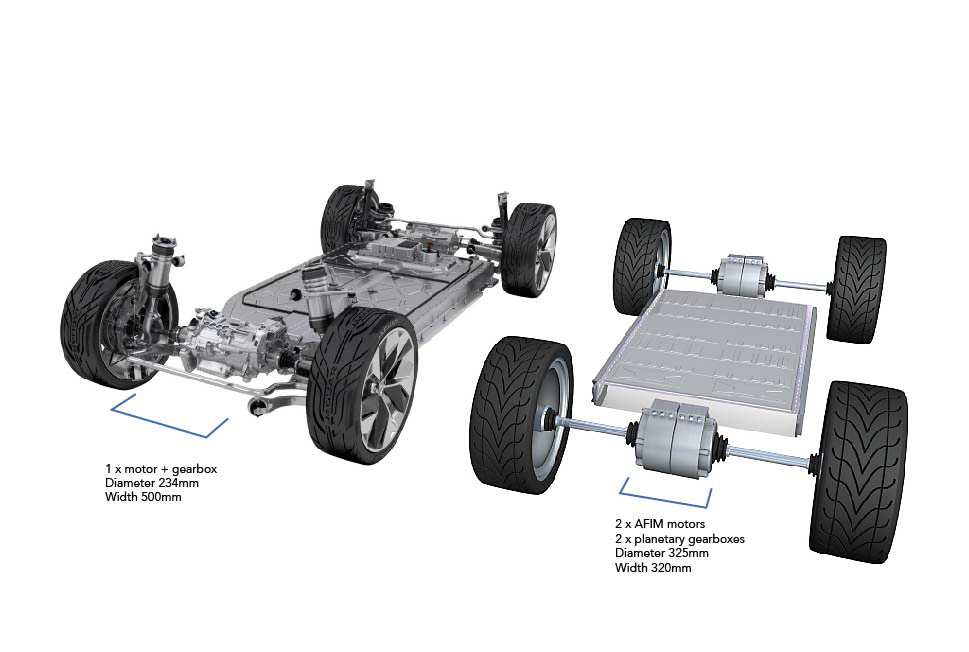
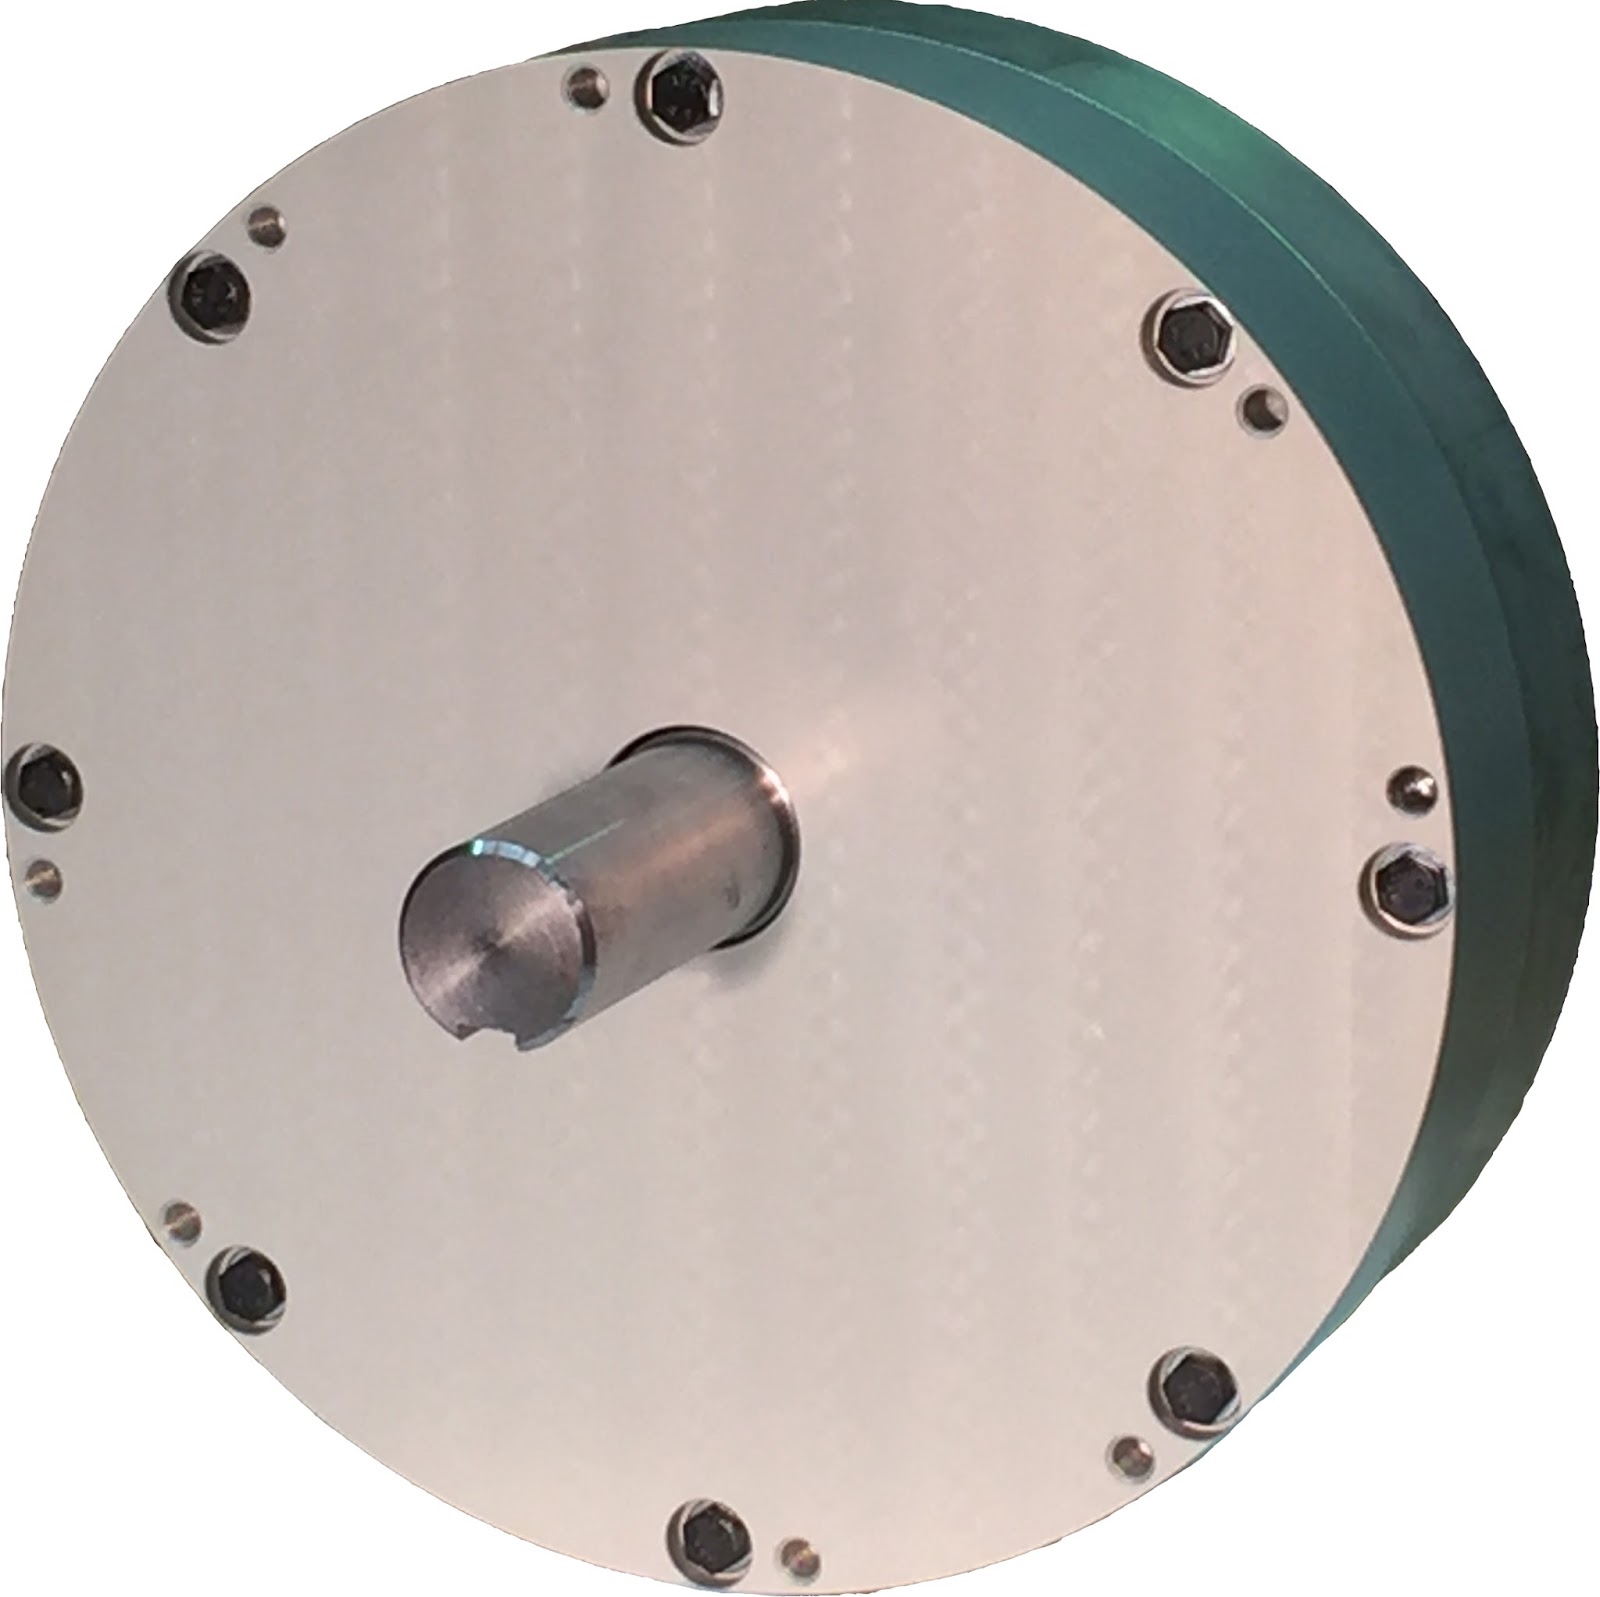
Evans Electric has previewed a next generation EV motor that it says will be licensed for production in 2017. The Axial flux asynchronous induction motor offers 90 kW of power, 300 Nm of peak torque and features very high torque density.

Evans Electric designed the new motor with integration, miniaturization and high energy efficiency in mind. It uses a double stator, single rotor axial air gap architecture with a patent pending solid core, copper disc rotor.

Overall, the size of the motor represents a reduction of 70%, while retaining the same level of performance. The motor has the same peak torque as a standard Tesla Roadster AC induction motor yet is only 1/3rd the volume due to a much shorter axial length. The oil-cooled 3 phase motor is designed to be integrated into the bellhousing of a multi-speed transmission.

The AFIM design is also well suited to wheel hub motor applications such as electric bus and military ground vehicles.

“Not only does the high power density of the axial air gap design give a cost advantage because less active material is required for a given amount of torque, but our copper rotor axial flux induction motor also has the significant cost advantage of eliminating the need for rare-earth permanent magnets.” said founder, Paul Evans.

The 4 person Sydney Australia based startup have been working on the AFIM design for a German OEM and has now opened their series A funding round.

More: Evans Electric

DARPA is developing smarter, faster armored ground vehicles

Today’s ground-based armored fighting vehicles are better protected than ever, but face a constantly evolving threat: weapons increasingly effective at piercing armor. While adding more armor has provided incremental increases in protection, it has also hobbled vehicle speed and mobility and ballooned development and deployment costs. To help reverse this trend, DARPA’s Ground X-Vehicle Technology (GXV-T) program recently awarded contracts to eight organizations.

DARPA's Ground X-Vehicle Technology (GXV-T) program seeks to develop groundbreaking technologies that would make future armored fighting vehicles significantly more mobile, effective, safe and affordable.

Radically Enhanced Mobility—Ability to traverse diverse off-road terrain, including slopes and various elevations. Capabilities of interest include revolutionary wheel/track and suspension technologies that would enable greater terrain access and faster travel both on- and off-road compared to existing ground vehicles.

Like previous autonomous off-road military vehicle prototypes, for example Carnegie Mellon University's "Crusher", (pictured below) all-wheel-drive in-wheel motor electric powertrains are a key enabling technology for these next generation vehicles.

“We’re exploring a variety of potentially groundbreaking technologies, all of which are designed to improve vehicle mobility, vehicle survivability and crew safety and performance without piling on armor,” said Maj. Christopher Orlowski, DARPA program manager. “DARPA’s performers for GXV-T are helping defy the ‘more armor equals better protection’ axiom that has constrained armored ground vehicle design for the past 100 years, and are paving the way toward innovative, disruptive vehicles for the 21st Century and beyond.”

Electromagnetic Anti-Lock Braking for Electric Vehicles

In part 2 of this series (Part 1) we'll take a closer look at electromagnetic braking as a replacement for mechanical friction brakes in hybrid and electric passenger cars.

Electromagnetic braking is very well established in industrial applications. From 400 tonne mine haul trucks to 300 km/h Bullet trains, electromagnetic 'friction' is used to slow these high performance vehicles with industrial strength reliability, so why shouldn't it also be used on comparatively light weight private passenger vehicles ?

Lets take a look at a few of the more familiar applications of electromagnetic braking. Japan's Shinkansen high speed rail network has the best safety record on the planet: beating conventional trains, automobiles and flying. Over the Shinkansen's 50-plus year history, carrying over 10 billion passengers, there have been zero fatality / injury since 1964. Clearly many factors contribute to this but obviously the train braking system plays an important role, especially given the maximum operating speed is 320 km/h (200 mph).

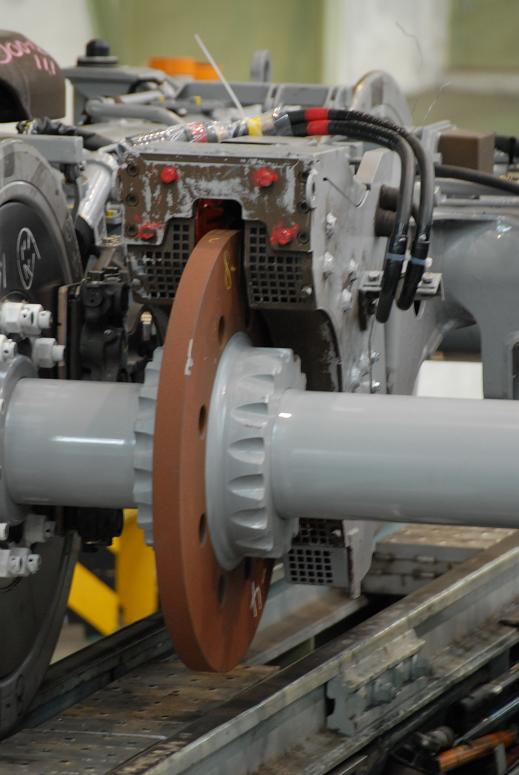
Bullet trains uses electricity to brake up to 640 tonnes down from 300 km/h at a controlled and predictable deceleration rate. Since 1984 all Shinkansen trains have used axial flux eddy current disc brakes (pictured above). These work along the same lines as an eddy current dyno where a steel brake rotor has electromagnets facing it, that when energised, induce eddy currents in the rotor which generates electromagnetic friction that converts the trains kinetic energy into heat.

With the only moving part being the rotor and no wear and tear from mechanical friction, eddy current brakes have proved incredibly reliable and no doubt contribute to the 100% safety record achieved by the Shinkansen rail system. Since 2007 next generation Bullet trains have moved to regenerative braking that uses the main traction motors which helps increase overall system efficiency.

Another very large vehicle that uses electromagnetic brakes is the 400 t class Liebherr T282B Mine haul truck. with a maximum operating weight of almost 600 tonnes, the T282B has no mechanical connection between the monster 90 liter V20 twin turbo diesel engine and the rear wheels.

Instead it takes advantage of high efficiency and maintenance free diesel-electric locomotive technology. Siemens provide two AC induction motors for the rear axle, engine mounted generator and the solid state computer controlled power inverters that are proven over millions of operating hours in trains. The main service brake electric retarders can slow the truck to a stand-still and provide precise speed control on descent using built in cruise control which works in both drive and retard modes.

The electric retarders can apply over 6,000 hp (4,489 Kw) worth of braking effort (the Diesel ICE maximum output is 'only' 3650 hp (2700 Kw). Like the Bullet train there is no battery storage system on-board so the regenerated energy is not stored for later use but is converted to heat via a stainless steel resistor grid in a systems called dynamic braking.

If ultra-reliable electromagnetic braking of 600 tonne vehicles hasn't convinced you then surely this last example will. Strictly speaking this is called magnetic braking as the source is permanent magnets, yet it is just as impressive.

Drop Tower amusement park rides feature up to 400 feet (120 m) towers with a carriage capable of taking up to 40 passenger aloft. Once 30 stories off the ground, the 25 tonne carriage is dropped and free-falls back down the tower reaching speeds of 105 km/h. Built by Swiss firm Intamin, the eddy current magnetic brakes pull the falling riders up at 2.5G from 100 to 0 km/h within 100 feet.

To put that into perspective, a Tesla Model S brakes from 100 to 0 km/h in 113 feet, weighs only 2.5 tonne and moves parallel to the ground, not hurtling head-first towards it.

The common threat between all the above braking applications is that mechanical friction brakes would simply not be capable of reliably doing the job. While these electric braking systems convert kinetic energy into heat, as do hydraulic friction brakes, using electromagnetic friction offers a non-contact method of braking that virtually eliminates maintenance and therefore reliability issues.

In the previous post we've seen evidence that hydro-mechanical friction brakes on hybrids and EVs have become redundant legacy systems primarily still required on vehicles because they provide mandatory safety systems. In order to allow electromagnetic braking to functionally replace systems like ABS & ESC not only do we need each wheel to have an electric motor to drive / brake each wheel independently, but also additional electromagnetic braking strategies other then just regeneration feeding kinetic energy into a battery pack.

Currently in hybrid and electric vehicles only a fraction of the electric motors full power is used for braking. For example, a Chevy Volt has 115 kw of electric motor power available for acceleration but only 60 kw for braking. Even a Tesla Model S with over 500 kw for acceleration is limited to 60 Kw maximum brake regeneration. The primary reason for this is battery cell charge limits. Most lithium ion batteries have asymmetric charge & discharge curves.

In order to allow full electric motor power to be applied in brake mode, alternative energy discharge methods are required. As we have seen in the examples provided above, there are several options from dynamic to eddy current braking and/or the addition of supercapacitors in parallel with the battery pack. With an electric motor for each wheel and full motor power available for braking, modulating the motors independently to perform anti-lock, stability control, emergency brake assist, automatic emergency braking and torque vectoring becomes a software project.

Siemens to show Roding Roadster Electric @ IAA 2015 [VIDEO]

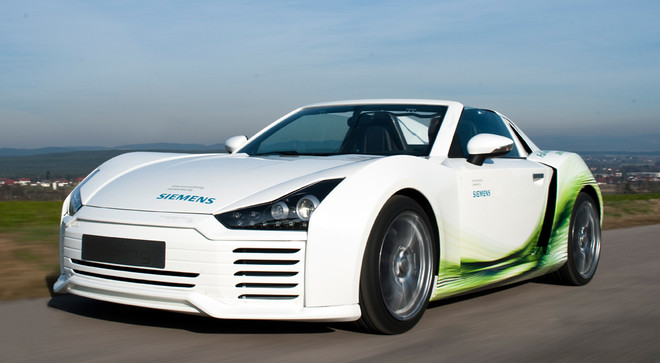
Siemens will show the wheel motor powered Roding Roadster Electric at the 2015 IAA (Internationale Automobil-Ausstellung) in Frankfurt Germany this month.

The Roding Roadster Electric is a hub drive powered research vehicle. Based on the Roding Carbon Cell, this innovative battery-powered drive train could be realized together with Siemens Corporate Technology. The prototypes used for this purpose were constructed without a mechanical brake at the rear axle, instead, braking is done by the electric motor.

The brake system is controlled by so-called Brake Blending, i.e., as circumstances require, the brake torque is automatically transferred from the electrically powered brake to the friction brake at the front axle. It is aimed to recuperate the entire potential energy in 70% of all braking processes.

  • Maximum power: 2 x 120 kW
  • Maximum torque: 2 x 1250 Nm
  • Lithium Ion Battery: 19,4 kWh
  • Unloaden weight: 1125kg (DIN-standard)

  • Wireless in-wheel motor system developed for electric vehicles

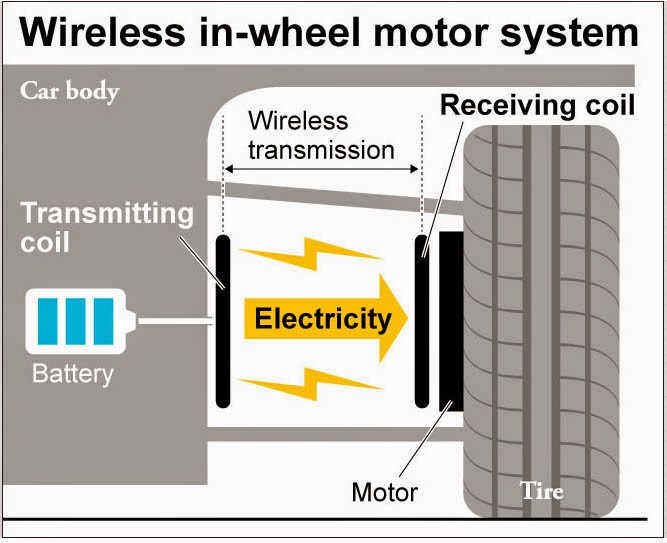
    Japanese researchers have successfully developed the world’s first in-wheel motor system for electric vehicles that transmits power wirelessly to run motors incorporated in each wheel.

    Hiroshi Fujimoto, an associate professor at the University of Tokyo specializing in electric vehicle control, and other researchers ran a vehicle equipped with the new system that transmits electricity wirelessly from an onboard power source to a coil attached to the wheel hubs.

    “This technology will pave the way for the development of advanced electric vehicles, including those that receive electricity wirelessly from transmitting coils that are embedded under road surfaces,” Fujimoto said. “It can be also applied to fuel-cell vehicles and industrial machinery.”

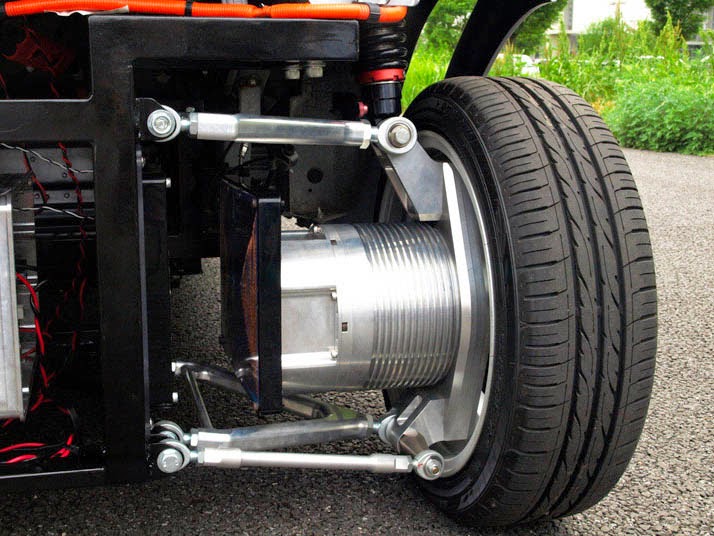
    The in-wheel motor, also known as wheel hub motor, is an electric motor that is incorporated into the hub of a vehicle's wheels to directly drive each wheel.

    Compared with conventional electric vehicles, the in-wheel motor model does not require a drive shaft, a component that takes power from a single source and mechanically transfers it to all the wheels to drive them. Thus, a car using the system could be built lighter and require less energy.

    Acceleration and braking for each wheel can also be controlled, which would help prevent mishaps such as skids.

    Current cars using in-wheel motors need wires to transmit electricity. The complex wiring distribution and its susceptibility to shorting out have remained a hurdle in developing such a vehicle for practical use.

    The research team’s wireless system transmits the electricity stored in the vehicle’s batteries through a transmitting coil to a receiving coil in the wheel hub, a distance of 10 centimeters.

    The researchers successfully ran a motor using a maximum of 3 kilowatts of electricity and sent control information to each wheel using standardized Bluetooth wireless technology.

    The rear-wheel-drive prototype car can, in theory, run at maximum 75 kph, the researchers said.

    Chevrolet-FNR autonomous EV concept

    Chevrolet has created a vision of what it thinks a full autonomous all-electric vehicle of the future might look like.

    Created by GM’s Pan Asia Technical Automotive Center the Chevrolet-FNR is an autonomous electric concept vehicle that boasts a futuristic capsule design. It has crystal laser headlights and taillights, dragonfly dual swing doors.

    The Chevrolet-FNR features an extremely aero design focused on low drag powered by AWD magnetic hubless electric wheel motors along with autonomous wireless charging. A laundry list of imaginary specification like range and power output has been provided.

    The Chevrolet-FNR is loaded with a range of sensors like roof-mounted radar that can map out the environment to enable driverless operation, Chevy Intelligent Assistant and iris recognition start. The Chevrolet-FNR can also serve as a “personal assistant” to map out the best route to the driver’s preferred destination.

    In self-driving mode, the vehicle's front seats can swivel 180 degrees to face the rear seats, creating a more intimate setting. The driver can switch to manual mode through the gesture control feature.

    NASA’s new Wheel Motor AWD Electric Robotic Car [VIDEO]

    The Modular Robotic Vehicle, or MRV, was developed at NASA’s Johnson Space Center in order to advance technologies that have applications for future vehicles both in space and on Earth. With seating for two people, MRV is a fully electric vehicle well-suited for busy urban environments.

    One of NASA’s key purposes for the project was to have access to a technology development platform. “This work allowed us to develop some technologies we felt were needed for our future rovers,” said Justin Ridley, Johnson Space Flight Center. “These include redundant by-wire systems, liquid cooling, motor technology, advanced vehicle control algorithms. We were able to learn a lot about these and other technologies by building this vehicle.”

    Just as NASA helped pioneer fly-by-wire technology in aircraft in the 1970s, MRV is an attempt to bring that technology to the ground in modern automobiles. With no mechanical linkages to the propulsion, steering, or brake actuators, the driver of an MRV relies completely on control inputs being converted to electrical signals and then transmitted by wires to the vehicle’s motors. A turn of the steering wheel, for instance, is recorded by sensors and sent to computers at the rear of the vehicle. These computers interpret that signal and instruct motors at one or all four of the wheels to move at the appropriate rate, causing the vehicle to turn as commanded. Due to a force feedback system in the steering wheel, the driver feels the same resistance and sensations as a typical automobile.

    Not having a mechanical linkage between the driver and the steering wheel introduces new risks not seen on conventional automobiles. A failed computer, or cut wire, could cause a loss of steering and the driver to lose control. Because of this, a fully redundant, fail-operational architecture was developed for the MRV. Should the steer-ing motor fail, the computer system responds immediately by sending signals to a second, redundant motor. Should that computer fail, a second computer is ready to take over vehicle control. This redundancy is paramount to safe operations of a by-wire system.

    MRV’s redundant drive-by-wire architecture allows for advanced safety and dynamic control schemes. These can be implemented with a driver operating either within the vehicle or by remote interface. In the future this system can be expanded to allow for autonomous driving

    MRV is driven by four independent wheel modules called e-corners. Each e-corner consists of a redundant steering actuator, a passive trailing arm suspension, an in-wheel pro-pulsion motor, and a motor-driven friction braking system.

    Each e-corner can be controlled independently and rotated ±180 degrees about its axis. This allows for a suite of driving modes allowing MRV to maneuver unlike any traditional vehicle on the road. In addition to conventional front two wheel steering, the back wheels can also articulate allowing for turning radiuses as tight as zero. The driving mode can be switched so that all four wheels point and move in the same direction achieving an omni-directional, crab-like motion. This makes a maneuver such as parallel parking as easy as driving next to an available spot, stopping, and then operating sideways to slip directly in between two cars.

    “This two-seater vehicle was designed to meet the growing challenges and demands of urban transportation,” said Mason Markee, also with Johnson. “The MRV would be ideal for daily transportation in an urban environment with a designed top speed of 70 km/hr and range of 100 km of city driving on a single charge of the battery. The size and maneuverability of MRV gives it an advantage in navigating and parking in tight quarters.”

    The driver controls MRV with a conventional looking steering wheel and accelerator/brake pedal assembly. Both of these interfaces were specially designed to mimic the feel of the mechanical/hydraulic systems that people are used to feeling when driving their own cars. Each device includes its own redundancy to protect for electrical failures within the systems. A multi-axis joystick is available to allow additional control in some of the more advanced drive modes. A configurable display allows for changing of drive modes and gives the user critical vehicle information and health and status indicators.

    Each propulsion motor is located inside the wheel and capable of producing 190 ft-lbs of torque. An active thermal control loop maintains temperatures of these high powered motors. A separate thermal loop cools the avionics, includ-ing custom lithium-ion battery packs.

    “While the vehicle as a whole is designed around oper-ating in an urban environment, the core technologies are advancements used in many of our robotic systems and rovers,” explained Mason. “Actuators, motor controllers, sensors, batteries, BMS, component cooling, sealing, and software are all examples of technologies that are being devel oped and tested in MRV that will be used in next generation rover systems.”

    The technologies developed in MRV have direct appli-cation in future manned vehicles undertaking missions on the surface of Earth’s moon, on Mars, or even an asteroid. Additionally, MRV provides a platform to learn lessons that could drive the next generation of automobiles.

    Torque Vector Steering Improves Electric Vehicle Energy Efficiency

    Germany's Karlsruhe Institute for Technology along with industry partner Schaeffler are researching improvements in electric vehicle energy efficiency by using brake steer or torque vector control of wheel motors to assist power steering.

    The project "Intelligent Assisted Steering System with Optimum Energy Efficiency for Electric Vehicles (e²-Lenk)" subsidized by the Federal Ministry for Education and Research (BMBF) focuses on a new assisted steering concept. In conventional vehicles, the internal combustion engine not only accelerates the car but also supplies on-board assist systems with energy; such as the assisted steering system, which reduces the strain on the driver at the wheel.

    In electric vehicles, this energy comes from the battery and also reduces the range as a result. In this research project by the collaborating partners, Karlsruhe Institute for Technology (KIT) and Schaeffler, the steering system is assisted in an energy-efficient manner by intelligent control of the drive torques transmitted to the individual wheels. The project is being sponsored by BMBF with a sum of around 0.6 million euros over 3 years and was started in January 2015.

    "The new assisted steering system would require less system components in an electric vehicle, this would mean savings in terms of weight and energy in an electric vehicle", explain project managers Dr. Marcel Mayer, Schaeffler, and Dr. Michael Frey, KIT. "This would mean that an electric car would be cheaper and have a greater range." Materials and production steps can be saved due to the potential optimization of the design and weight.

    The basic idea of the e²-Lenk project is simple: The wheels in an electric car will be driven individually by electric motors in contrast to a car with an internal combustion engine where all the wheels are provided with equal force. If the wheels on the left side transmit more drive torque to the road than those on the right side, this will result in acceleration of the vehicle to the right without the need to turn the front wheels or consume additional energy for steering.

    Tracked vehicles or quadrocopters steer using the same principle. "Steering assistance can be provided while driving by means of an intelligent control system and suitable wheel suspension", says Schaeffler engineer Mayer, Manager of the Automatic Driving Working Group, which is carrying out research as part of the collaborative research project SHARE (Schaeffler Hub for Automotive Research in E-Mobility) at KIT. "Only steering when stationary remains a challenge with conventional designs."

    "The assisted steering system is part of the drive train with our approach", explains Frey who is researching at KIT's Institute of Vehicle Systems Technology. Steering the front wheels is carried out without using additional energy. "We also want to significantly increase the quality of driving. Customer benefit, comfort, safety and reliability go hand in hand here."

    As part of the project, functional demonstrators are being built, with which the concepts can be validated and optimized in experiments. It is also planned to implement the system in last year's Formula Student racing car KIT built by the university group KA-RaceIng with the participation of the students.

    e²-Lenk is the first publicly subsidized joint project as part of the collaborative re-search project SHARE at KIT between Schaeffler Technologies AG & Co. KG and KIT. This joint project is being managed at KIT's East Campus in a joint project management office run by SHARE at KIT and the Institute of Vehicle Systems Technology (FAST).

    Schaeffler and KIT are partners in the Leading Edge Cluster Electric Mobility South-West (ESW), which connects over 80 stakeholders from science and economics in the region Karlsruhe – Mannheim – Stuttgart – Ulm. The cluster strategy of the ESW cluster aims to achieve intensive regional collaboration in the field of electric mobility by means of new approaches and forms of cooperation. As a result, knowledge is developed, consolidated and ultimately advantages are achieved in international competition.

    Axial Flux Induction Motor for Hybrid and Electric Cars [VIDEO]

    EV Powertrain start-up Evans Electric is rumoured to have been working on some interesting electric vehicle projects recently.

    The team have developed a world-first copper rotor axial flux induction motor for automotive applications. The patent pending design has torque density on par with comparable axial air gap synchronous motors but without the expense of rare-earth permanent magnets.

    Disc-shaped Axial flux motors are steadily making inroads into electric vehicle powertrains with Renault, Koenigsegg and Bugatti all looking to incorporate them into future models.

    Evans Electric were also rumoured to have been hired by an OEM to help develop the architecture of a series hybrid powertrain based on in-board AFIMs with all-wheel-drive torque vectoring powered by a supercapacitor / li-ion battery energy storage system.

    No news on which OEMs head these projects but they are believed to be EU headquartered.

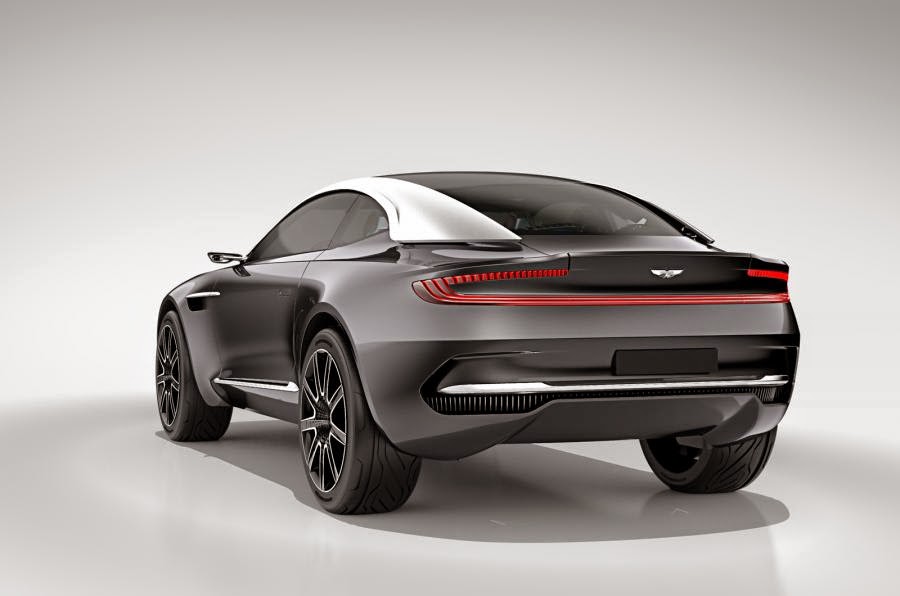
    Aston Martin début all-electric all-wheel-drive DBX Concept

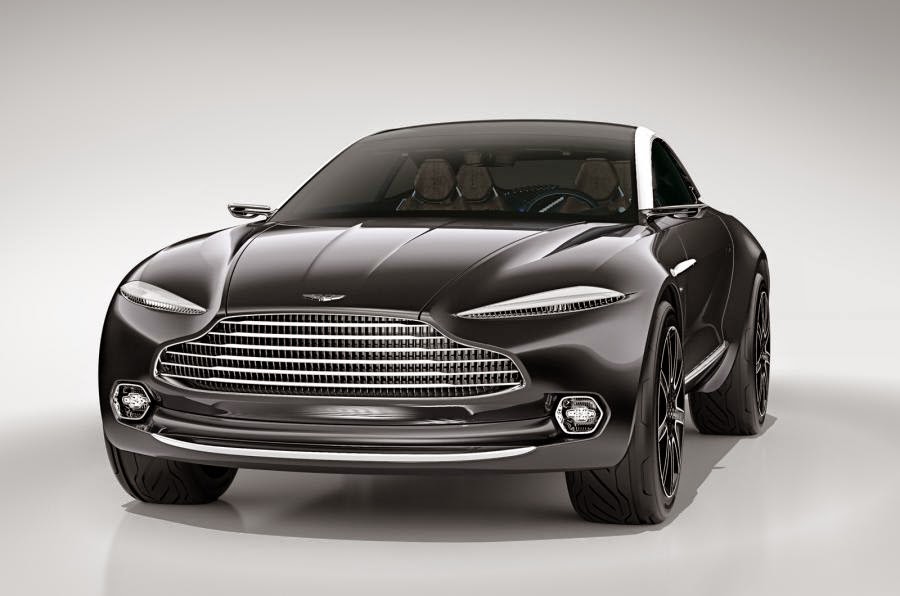
    Aston Martin has surprise all at the 2015 Geneva Motor Show with the debut of an all electric DBX Concept.

    Aston Martin is calling the DBX Concept a high luxury GT that fits the description of a crossover coupe. Far from a production ready vehicle, the concept is just a design study for the time being, but Aston does admit there is a market for such a vehicle.

    The DBX Concept is an all-wheel drive crossover high luxury GT that uses in-board electric wheel motors at all four corners powered by lithium sulphur cells. Steering is a drive-by-wire system and both the driver and passenger have head-up displays surrounded by auto-dimming ‘smart glass’.

    The DBX Concept can accommodate four adults and all the cargo they could ever want since there is a traditional rear cargo area as well as a front trunk occupying the place usually reserved for a ICE.

    Souce: Autocar

    GM developing a high-performance electric AWD system for next-gen Cadillacs

    According to Edmunds, General Motors is developing a high performance electric all-wheel drive system for next-gen V-Series Cadillac models and maybe their crossovers. This system could make its way into other GM Alpha-platform-based vehicles such as the Cadillac ATS and Chevrolet Camaro, and possibly a Corvette derivative.

    All-wheel drive has become a must-have for high-performance luxury car buyers, and Audi, BMW, Mercedes-Benz and Porsche are ahead of the game with their AWD-equipped vehicles. Cadillac, however, lags behind this trend, having just introduced the 455-horsepower ATS-V and 640-hp CTS-V, both rear-wheel-drive sedans. Cadillac is also lagging in its offering of electrified fuel-efficient models.

    An electric all-wheel-drive system, known in the industry by the acronym e-AWD, can potentially boost fuel economy in many future vehicles and help expand their plug-in hybrid offerings, however, the system GM desires is many years in the future.

    Joe Slenvak, director of powertrain electrification for North America at Robert Bosch, told Edmunds that adding electric all-wheel drive to the front wheels of a rear-drive car has challenges.

    "When you put the electric axle drive in the front, you have a lot of crossmembers and things that are in the cradle that you have to work around. It would be a little bit hard to do (but) I think you could do it," Slenvak said.

    Sounds like an application perfectly suited to in-wheel motors.

    Slenvak said a vehicle could be retrofitted to add that system. He would not say if Bosch is developing an electric all-wheel-drive system for GM's rear-drive cars.

    Source: Edmunds

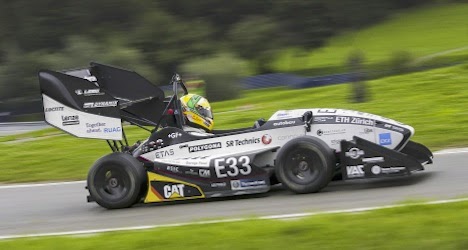
    Swiss electric car sets acceleration World Record

    An electric racing car developed by students at ETH Zurich and the Lucerne University of Applied Sciences and Arts on Monday set a world record for acceleration, the universities announced.

    The “grimsel” car sped from zero to 100 kilometres an hour in just 1.785 seconds, at a military airport in Dübendorf in the canton of Zurich, smashing the the previous record.

    The previous record of 2.13 seconds was set by Delft University of Technology in the Netherlands.

    Operated by a student team from the Academic Motorsports Club Zurich (AMZ), The grimsel car, reached a speed of 100 km/h in less than 30 metres, ETH Zurich, the Swiss Federal Institute of Technology, said in a news release.

    Thirty students from the two swiss universities developed and built the racing car in less than a year.

    Weighing just 168 kilograms, the carbon-fibre vehicle generates 200 horsepower through four-wheel drive, ETH said.

    Four specially designed wheel hub motors create a total torque of 1,630 Newton metres (Nm), with torque distribution controlled individually for each wheel to maximize acceleration, the university said.

    AMZ was founded in 2006 ivy ETH students and produces a prototype racing car to compete in various student formula competitions in Europe every year.

    The grimsel car will be presented to the public at “Student Power Day” on November 9th at the ETH Hönggerberg campus, with test rides planned between noon and 2pm.

    BMW-Toyota sports car to use all-wheel drive and supercapacitors

    BMW's newly minted alliance with Toyota will result in a hybrid all-wheel-drive Z4 / Supra replacement, complete with supercapacitor technology for increased performance, Autocar reports.

    The car will have a front-engined direct-injection four cylinder turbo and electric motors driving all four wheels. The supercapacitor system will be derived from technology first seen in Toyota's Hybrid Supra HV-R in 2007 when it won the Tokachi 24 hour race and more recenly Toyota's Le Mans LMP1 race cars.

    BMW will supply the 2.0 liter turbocharged engine combined with electric motors produced by BMW at its engine plant in Munich while a Toyota-developed electronics system is expected to provide torque-vectoring capability.

    With the car expected to have a front mounted engine and sequential manual gearbox in a conventional longitudinal powertrain layout it will be interesting to see what type of electric motors BMW deploy to drive the front wheels, perhaps in-wheel motors?

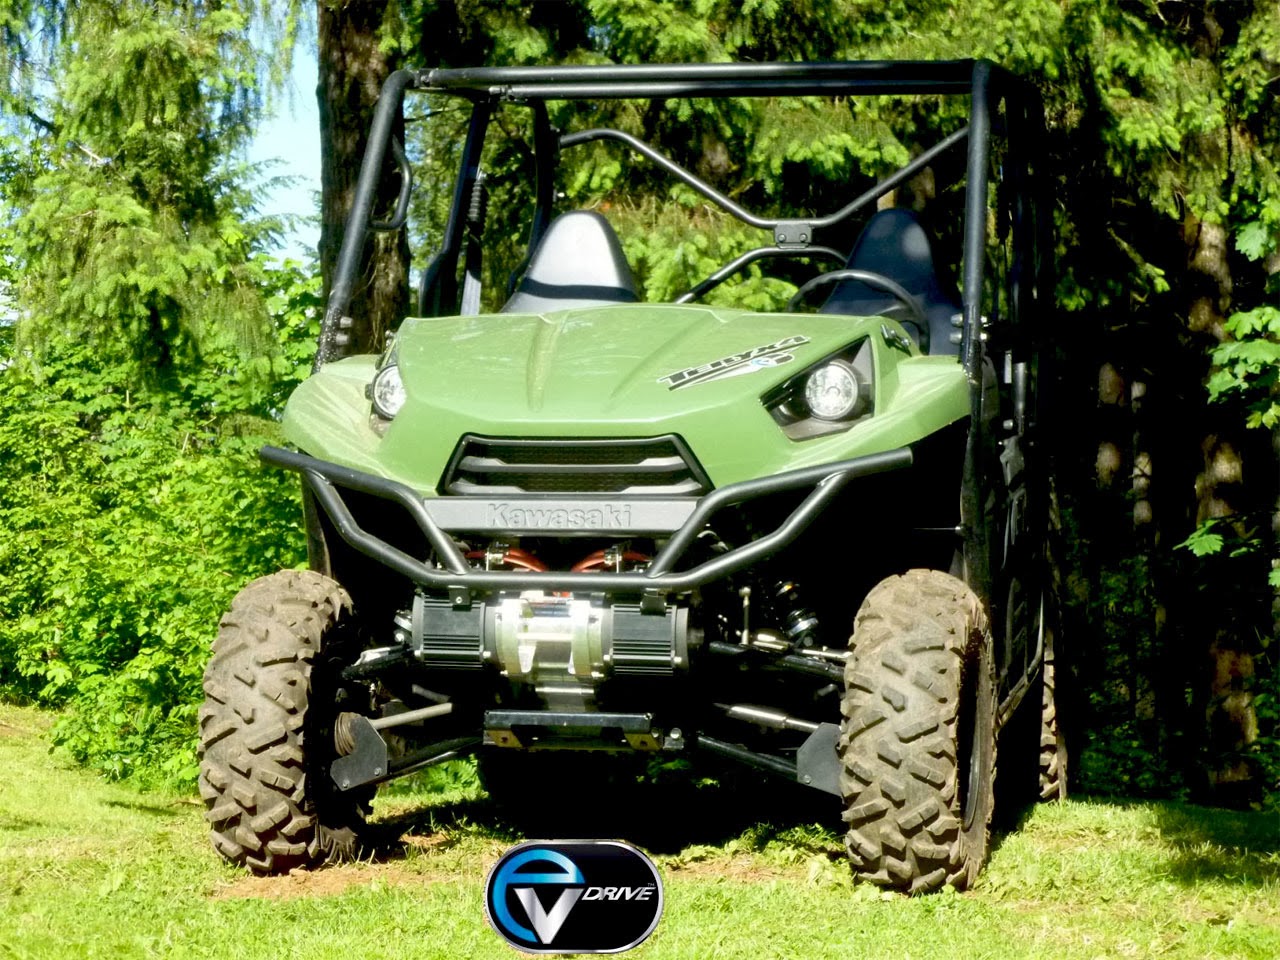
    EVDrive Demo a UTV with 4-Wheel Motor Torque Vectoring [VIDEO]

    EVDrive completed development and demonstrated a powersports industry first, an "electric 4-wheel 4-electric-motor torque vectoring technology" called Terra-Torque-Drive™, specifically geared to 4-wheel off-road powersports vehicles, such as for the rapidly growing market segment of side by side Utility Terrain Vehicles or UTVs. After taking recent demo rides in the EVDrive-UTV tech demonstrator, powersports industry insiders, such as UTV OEM reps and UTV racers enthusiastically agree, that the Terra-Torque-Drive™, technology would beat almost all of today's top "gas/mechanical powered" 4wd UTVs. OEMs now have the opportunity to license this unique technology for integration into their own future powersports side by side UTV vehicle offerings.

    Approximately 323,000 UTVs were retailed in North America in 2012, according to Power Products Marketing (PPM), a market research firm. PPM found consumer models (for example: Polaris RZR XP900) accounted for around 35% of total sales; Prosumer models (example: Deere XUV825i) garnered around 55% share, and commercial models (example: Bobcat Toolcat) were responsible for about 5% of sales. Industry insiders concur that the new EVDrive technology could apply to all 3 market segments. Compared to the top UTVs sold today, a Terra-Torque-Drive™, powered UTV with EVDrive Range Extender (REX) installed would excel in these areas:

    1 - Highest efficiency 4wd drivetrain on any UTV today (least mechanical losses)
    2 - Adjustable hill descent control (accomplished via an "electric engine braking" called "regen" putting energy back into the vehicles battery system from each of the 4 wheels)
    3 - Dynamic torque vectoring modes both for high and low speed operation, e.g. industry unique "Zero Radius Turning" and high speed active torque vectoring allows for better and safer handling off-road
    4 - Torque and power from -100 to +100% can be dynamically sent to any wheel, in either direction, in any combination, at any time.
    5 - True Series hybrid with optimized internal combustion engine powered REX to allow for longer range matching or exceeding gas powered UTVs sold today. (REX is a high voltage specialized generator- LPG, gas or diesel powered REX engine easily adaptable, no mechanical connections to vehicle)
    6 - 120vac power from onboard battery pack, backed up with the REX for general utility use
    7 - Lower cost to maintain and operate - superior fuel economy, estimated average 50-100% better – for short trips, no fuel may be needed at all – plug-in to standard electric car chargers.
    8 - Superior straight-line and rough loose material, curvy trail acceleration
    9 - Greater river depth traversal possible due to completely sealed liquid cooled e-motors/power electronics.
    10 - Stealthy low noise operation in electric only mode e.g. wildlife observation & hunting
    11 - Torque vectoring software platform allows new traction capabilities to be supported like "apps" without costly mechanical NRE expenses to the OEM – OEM can provide customers software updates for new capabilities.

    EVDrive chose the 4-seat Kawasaki Teryx4 as a tech demonstration platform because of its short wheelbase, smaller turning radius, and large break over angle to minimize getting hung up on obstacles. EVDrive modified this UTV with complete removal of the gas engine and AWD mechanical drivetrain and replaced with a 160hp peak total version of the Terra-Torque-Drive™. Unlike the stock Kawasaki Teryx4 UTV mechanical AWD drive, no additional mechanical losses are incurred in the Terra-Torque-Drive™, regardless of AWD mode from lack of transmission, driveshafts and differentials. "Off-road UTVs are ideally suited to our torque vectoring technology where only single fixed speed reduction is required per motor-wheel to attain 55-75mph top-speeds with the type of high RPM brushless motor technology we employ," said COO, co-founder, Steve Tice.

    The Terra-Torque-Drive™, is a customized version of the general and modular EVDrive-Train architecture™ (http://bit.ly/EVD-Arch) used on all EVDrive conversion projects, with an in-house developed scale-able torque vector software platform added running on the EVDrive VCU (vehicle control unit), which supports new traction modes with inputs from all driver controls plus vehicle sensors such as accelerometers, etc. Some planned traction modes, that go beyond what is currently running on the demonstrator: auto dynamic terrain type posi-traction control, variable inclination angle offset descent control, zero radius turns on incline, emergency 4-wheel panic braking/stop & boulder climbing.

    The Terra-Torque-Drive™, powered e-UTV demonstrator uses 4 of the sealed liquid-cooled EVDrive EVD35 35kW/47HP peak drive sub-systems, de-tuned to ~30kW/40HP each or delivering a total of ~160HP/120kW peak. At each motor shaft, ~66 ft-lbs peak torque is delivered. The 4 gearboxes allow ratio changes with off-the-shelf gearsets. With the currently installed single speed gearsets, at the CV joint of each wheel, a whopping 726 ft-lbs peak torque is delivered. This is the kind of torque necessary to perform Zero Radius Turns with a fully loaded vehicle and perhaps even some extreme rock climbing. "With these gearsets, a top speed of 45mph is achieved with acceleration to this speed of less than 4 seconds if you get good traction – at zero speed all 4 wheels will break loose on dry asphalt!" said EVDrive's CTO & co-founder, Bob Simpson.

    In the accompanying video to this press release, some of the e-UTV tech demonstrator more technical features are revealed, such as: control touch screen for the Terra-Torque-Drive™, specifically the interface to the in-house developed VCU, shown in accompanying picture links below, and optional engine sound synthesis unit some OEMs expressed interest in, with 2 sounds demonstrated in the video, a gas turbine and V-twin motorcycle sound.

    Addition of the15kW REX not only gives the UTV full performance and range to match and exceed top UTVs on the market but also offers a feature the competition does not, that is 120vac of electrical power anywhere you need it. "With the REX sub-system part of the Terra-Torque-Drive™, a hybrid UTV can be a true swiss-army-knife UTV, able to deliver power in remote locations for construction/utility/ranch applications, run silent for hunting/wildlife observation & with full-time 4wd torque vectoring, can deliver off-road handling and performance for sports/recreation, in summary, addressing all needs in the consumer, prosumer and commercial markets," said CEO, Steve Tice.

    "Similar to our 25kW REX technology installed in our Series-PHEV BMW325 tech testbed -> http://bit.ly/PHEV-BMW-3-series but smaller, our custom high voltage 15kW-single cylinder (ICE) powered REX for the UTV is located between the rear seats – so with this sub-system, competing against top 4-seat UTVs in range will not be a problem - certainly the performance meets and beats stock UTVs we have tested" said EVDrive's CTO Bob Simpson. The REX gas engine can be modified to run on LPG as well offering additional emissions and operational cost advantages. EVDrive's REX technology supporting the hybrid e-UTV development has been already designed & proven in EVDrive Series PHEV BMW 325i Technology Testbed here shown sealed below rear spare tire floor - no protrusion above stock floor as shown in pictures at link included above.

    EV West is partnering with EVDrive to deploy and demonstrate Terra-Digital-Torque-Steer™ all-wheel torque vectoring technology on full-size off-road vehicles. EV West is known for many milestones; e.g. Builders and drivers of the record breaking all-electric BMW 3-series street sedan at the Pikes Peak International Hill climb and builders of first ever electric off-road race car to run the Baja Mexican 1000 race in the National Off Road Racing Association's series.

    SIM-Drive Develop 4 motor AWD electric Toyota 86 [VIDEO]

    The EV SIM-86e, a Toyota 86 developed by SIM-DRIVE, was exhibited at the Odaiba Motor Fes. The car is an 86 based EV, with all 4 wheels powered by independent motors.

    Technical specifications haven't been released (in English at least) but we can make some educated guesses. The AWD EVs developed by SIM-Drive to date, SIM-Lei, SIM-Wil & SIM-Cel have all used direct drive in-wheel motors. We can see from the picture below, the standard friction brakes are visible in the wheels so the SIM-86e must be running in-board motors.

    In developing the SIM-86e, Tajima Motor Corporation used E-RUNNER technology, which the company has been developing for racing vehicles to participate in the Pikes Peak International Hillclimb. TMC Chairman of the Board and SIM-Drive President and Director Nobuhiro Tajima explained:

    “Since our development of a 4WD automobile with a twin engine, we have been playing with such car-control technology as multiple power sources and 4 independent motors. In the SIM-86e we have thoroughly employed the control know-how cultivated through developments to E-RUNNER technology.”

    While the Pikes Peak winning E-RUNNER was all-wheel-drive, it used only two motors driving the wheels through a differential on each axle. The motors were supplied by GKN and belived to be 2x AFM-240 Axial Flux motors, each capable of 335 kw (455 hp) and 1200 Nm Peak. As the GKN Evo motors are not suitable for in-wheel mounting we might speculate that the SIM-86e may be running 4x in-board AFM-140 Axial Flux motors driving the wheels via standard half-shafts, with or without gear reduction.

    “This year there were some wet roads, and for that reason our times didn't improve. However, with next year’s dry conditions, I think it may be possible to achieve a new course record. Also, our efforts for next year’s car are making it compatible with a fast charger, meaning we will get technological feed back for product version EVs as well. Both for practical reasons and in times of crises, EV’s clearly need to have the ability to charge quickly. I’m confident that fast charging technology for harsh motor sports conditions will be useful for developing the product versions to come.”